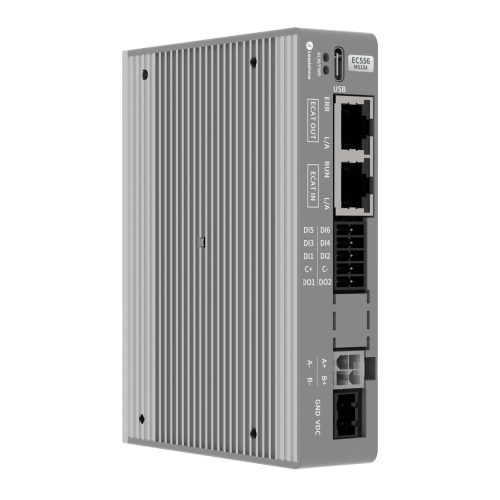
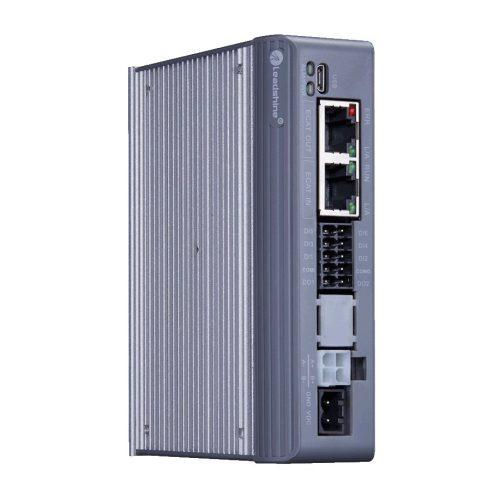
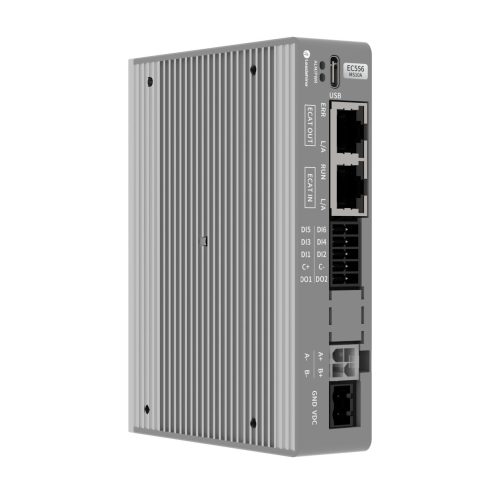
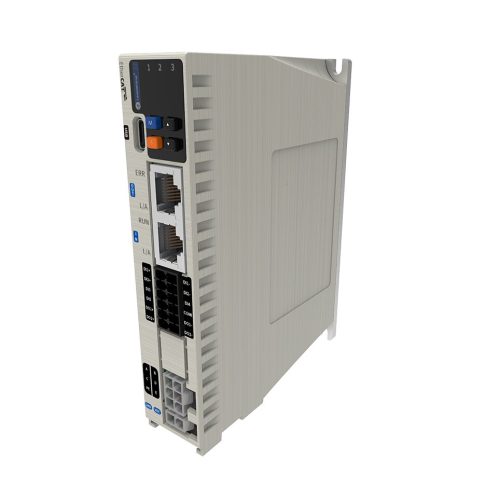
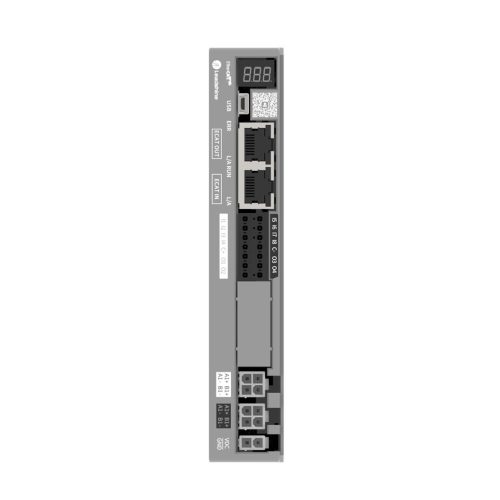
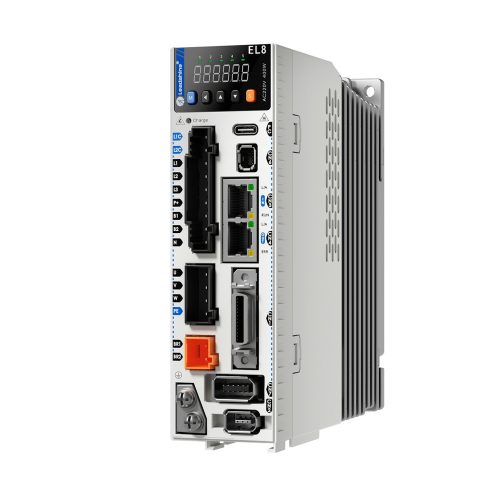
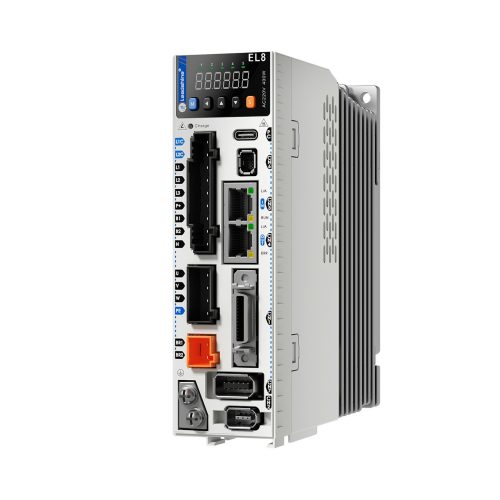
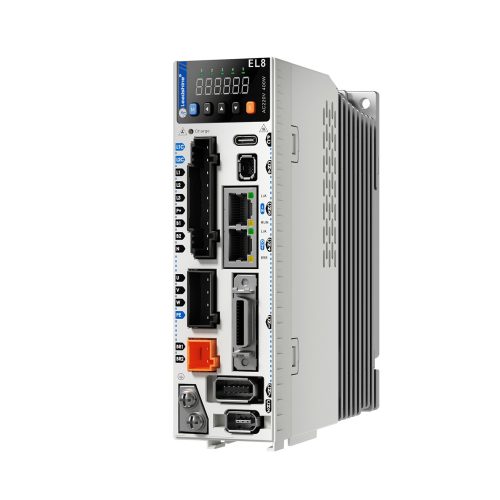
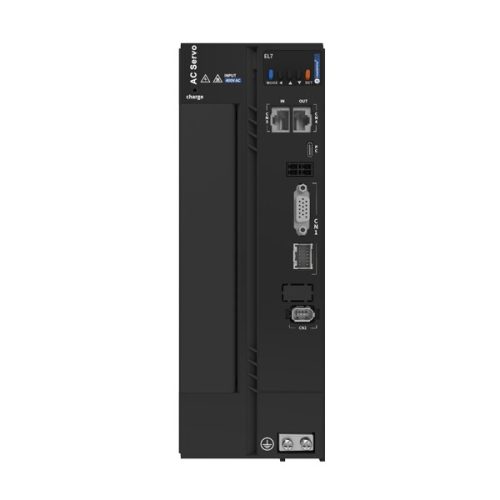
Leadshine’s drives with EtherCAT communication interface conform to CiA 301 application layer and CiA 402 device profile for drives and motion control, which use CANopen over EtherCAT (CoE) protocol. Connected in an EtherCAT network, two or more drives can be set at the same physical address, and the EtherCAT controller will automatically set the slave IDs. The communication cycle time is up to 250 µs (default). The terminator resistor switch is not required for EtherCAT drive. Currently, Leadshine can provide several EtherCAT drive models such as EM3E, CS3E and EL7-EC, except the servo drives that use a low voltage power supply (24–70 VDC).

EtherCAT
EtherCAT

EtherCAT

EtherCAT
EtherCAT
EtherCAT

EtherCAT
EtherCAT

EtherCAT
EtherCAT

EtherCAT

EtherCAT

EtherCAT

EtherCAT
EtherCAT
EtherCAT
EtherCAT
EtherCAT

EtherCAT
EtherCAT
EtherCAT

EtherCAT

EtherCAT
EtherCAT